De Montfort University engineer Meisam Abdi has won a research fellowship to develop 3D printed artificial muscles that could let soft robots move, sense and harvest energy.
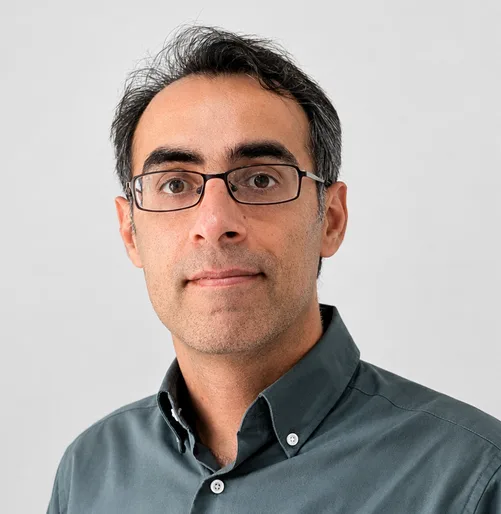
Abdi, a Senior Lecturer in Design for Additive Manufacturing at the Leicester university, is one of just eight engineers across the UK to receive a 2026/27 Royal Academy of Engineering/Leverhulme Trust Research Fellowship. The award pays for a replacement academic to take over his teaching and administration, freeing him for up to a year of full-time research on a project titled Additively Architected Piezoelectric Metamaterial Muscles for Sustainable Soft Robotics. The project builds on his research in topology optimization and printed lattice structures, and before De Montfort he was a post-doctoral research fellow at the University of Nottingham’s Centre for Additive Manufacturing.
The motivation is where robots are heading. Most still rely on rigid mechanical components, yet they are increasingly expected to work closely alongside people in hospitals, care settings, homes and workplaces, and researchers want them softer, safer and more adaptable.
“If we want people to interact safely with robots in places such as hospitals, we need to move away from completely rigid structures and think about how we can give robots some of the attributes we see in living systems,” said Abdi.
He takes his cue from how human muscle works but is not trying to copy its anatomy. Instead he will design architected structures whose geometry gives them particular properties. Combinations of piezoelectric, conductive and structural materials and architectures will be modelled with computer-aided engineering, then printed and tested in the laboratory to see how they respond to electrical stimulation.
Piezoelectric materials convert mechanical deformation into electrical energy and also deform when an electrical field is applied, which makes them a natural fit for a muscle that both moves and senses. The problem is that existing high-performance piezoelectrics are often relatively stiff and brittle, and some of the most widely used ones contain lead, which works against soft, flexible and more sustainable designs. Abdi plans to get around that by combining material composition with specially designed printed cellular structures, so the finished muscle reaches the required properties while staying soft and flexible.
The longer-term target is an artificial muscle that produces movement, senses its environment and harvests small amounts of electrical energy from mechanical movement or vibration. Replicating several functions of living muscle at once remains a major challenge in soft robotics, even with significant research already under way in the field.
“My ambition during the fellowship is to develop a prototype that demonstrates what is possible and can provide the foundation for further research,” he said.
Source: De Montfort University